Reading Notes
粗读 / 精读
已生成 src/paper-notes/gaussian-art-3dv2026/coarse.md
论文粗读笔记
用于快速判断论文定位、问题设定、核心方法、实验结论和是否值得精读。
论文粗读笔记:GaussianArt: Unified Modeling of Geometry and Motion for Articulated Objects
1. 基本信息
- 作者 / 机构:Licheng Shen 等;BAAI、清华大学、NTU、北理工、华中科技大学。
- 年份 / 会议:2026 / 3DV。
- 论文链接:OpenReview;arXiv PDF。
- 阅读模式:粗读。
2. 一句话定位
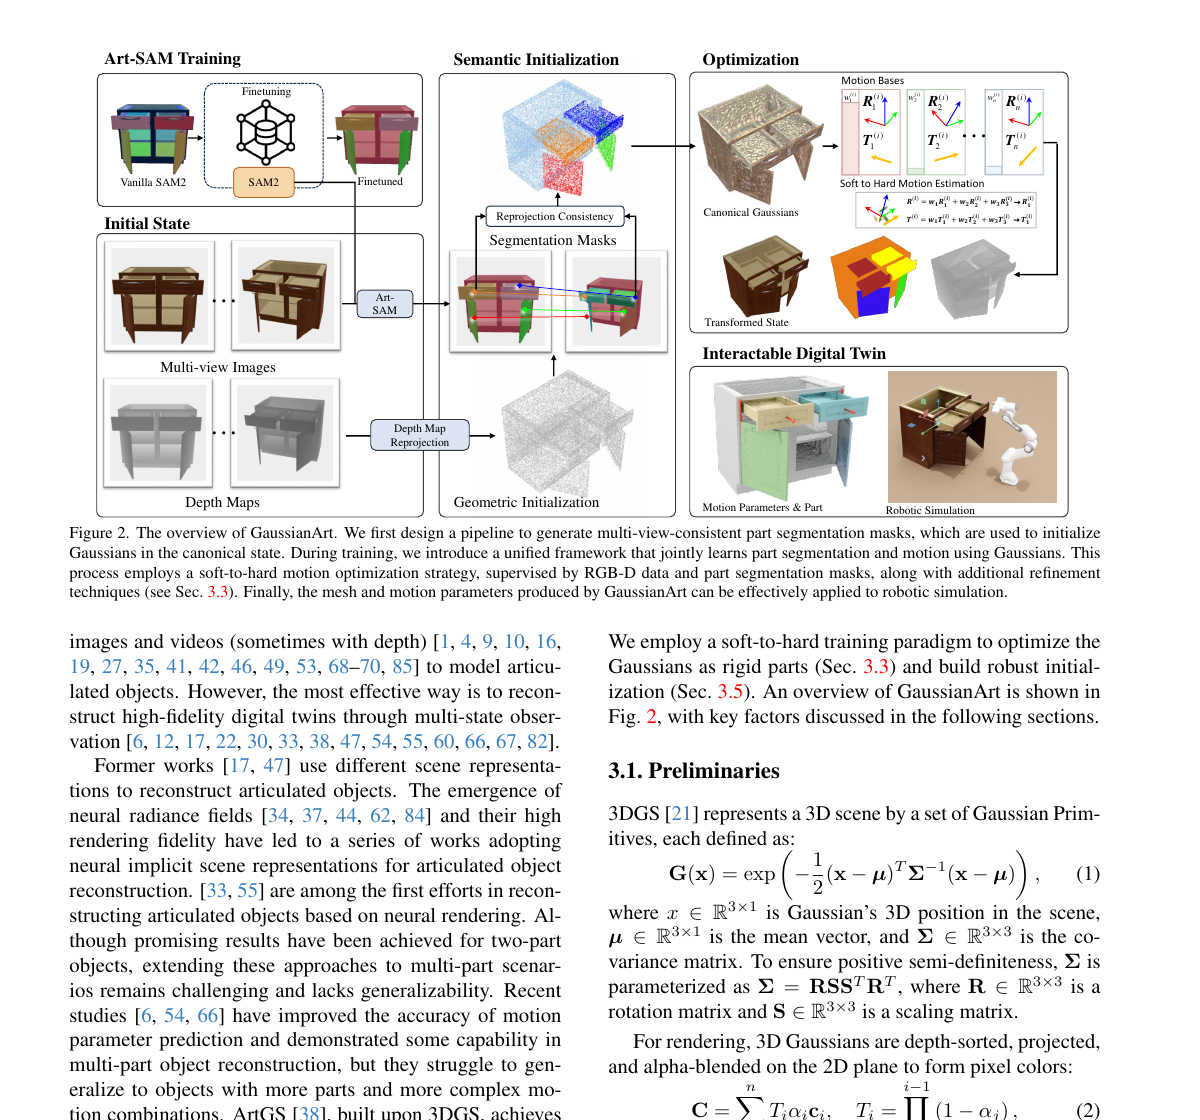
GaussianArt 用 articulated 3D Gaussians 统一优化 part geometry 与 motion,不再先在多个状态各自重建 shape、再通过 post-hoc alignment 推 articulation;同时给出覆盖最多 20 parts 的 MPArt-90。
3. 问题设定
- 输入:同一 articulated object 在两个状态下的多视角 RGB-D、已知相机内外参,以及生成的跨视角一致 part-level masks。
- 输出:canonical Gaussian geometry、part assignment、articulation axis / motion 与可交互数字孪生。
- 面向 complex multi-part articulation,不是从单 RGB 直接求某物体的 6DoF pose。
4. 方法概览
- 以 multi-view-consistent part segmentation 初始化 canonical Gaussians。
- 每个 Gaussian 绑定部件权重与 articulation parameter,统一拟合多状态观测。
- L0 regularization 强化 part assignment,trajectory regularization 用匹配的跨状态 3D 点约束 motion learning;soft-to-hard 优化提高部件可解释性。
5. 实验概览
- MPArt-90:90 objects、20 categories,包含 2–20 个部件。
- All-90 上,Axis Angle Error 12.17(ArtGS 24.34);static / moving CD 为 2.68 / 5.46(ArtGS 11.57 / 380.29)。
- 去掉 part segmentation,Axis Angle Error 变为 28.60,moving-part CD 186.67,显示 initialization 是决定性条件。
6. 优缺点与启发
优点
- geometry 与 motion 联合学习,能从结构上避免 post-hoc 运动分解漂移。
- MPArt-90 专门揭露既有方法在 6+ parts 的失效,不只在 2–3 parts 上比较。
缺点 / 风险
- 依赖 multi-view part masks 和多状态观测;中间 motion state 缺少直接约束会造成极端开合失真。
- 结果是数字孪生 / motion estimation,不能直接替代单帧 object pose system。
7. 值得精读的点
Table 2 显示 part segmentation 对 motion error 的影响远大于 L0 / trajectory 正则;对于 articulated pose,先正确分部件通常比后端优化器更重要。