Reading Notes
粗读 / 精读
已生成 src/paper-notes/omnishape-icra2025/coarse.md
论文粗读笔记
用于快速判断论文定位、问题设定、核心方法、实验结论和是否值得精读。
论文粗读笔记:OmniShape: Zero-Shot Multi-Hypothesis Shape and Pose Estimation in the Real World
1. 基本信息
- 作者:Katherine Liu、Sergey Zakharov、Dian Chen、Takuya Ikeda、Greg Shakhnarovich、Adrien Gaidon、Rares Ambrus
- 会议:ICRA 2025
- 论文:arXiv:2508.03669
- 项目:OmniShape
2. 一句话定位
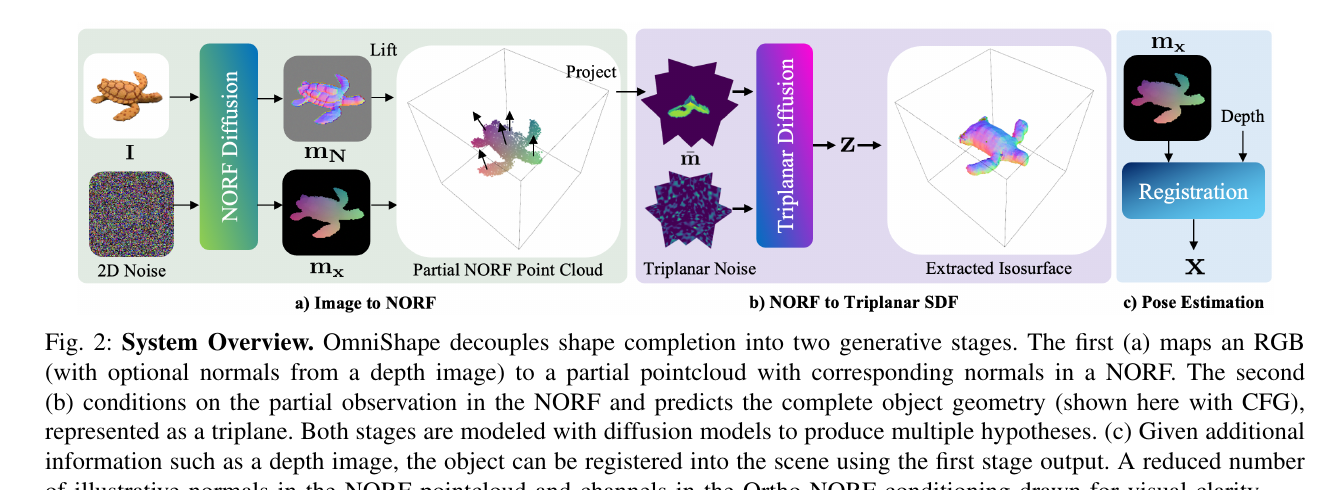
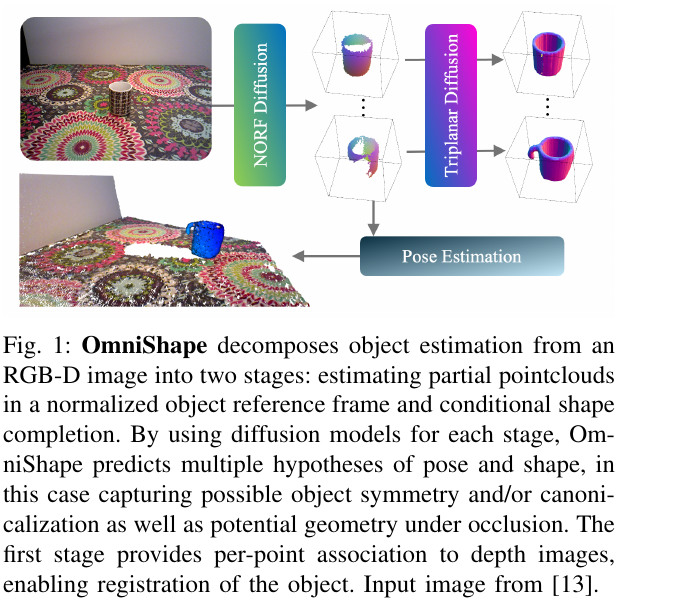
OmniShape 用两个条件 diffusion models 先采样相机视角下的 partial NORF point cloud,再补全 triplanar neural field;每次采样得到一个可能的 shape–pose hypothesis,最后借助可选 depth / normal registration 放回真实场景。
2.1 论文图表导读
3. 方法流程
- 从单张 RGB 与对象 crop 预测可见表面的 partial NORF point cloud。
- 第一阶段 diffusion 对局部几何和姿态不确定性采样。
- 第二阶段 diffusion 以 partial observation 为条件,生成 triplanar shape field。
- 提取完整 mesh / point cloud。
- 使用预测 normals 或可选 depth 做 metric registration。
- 重复采样得到多个 hypotheses,并以 observation inlier 等规则选择。
NORF 将点表示在与相机 / 观测关联的规范框架中,使 pose 和 shape 不必被完全拆成两个孤立任务。
4. 结果速览
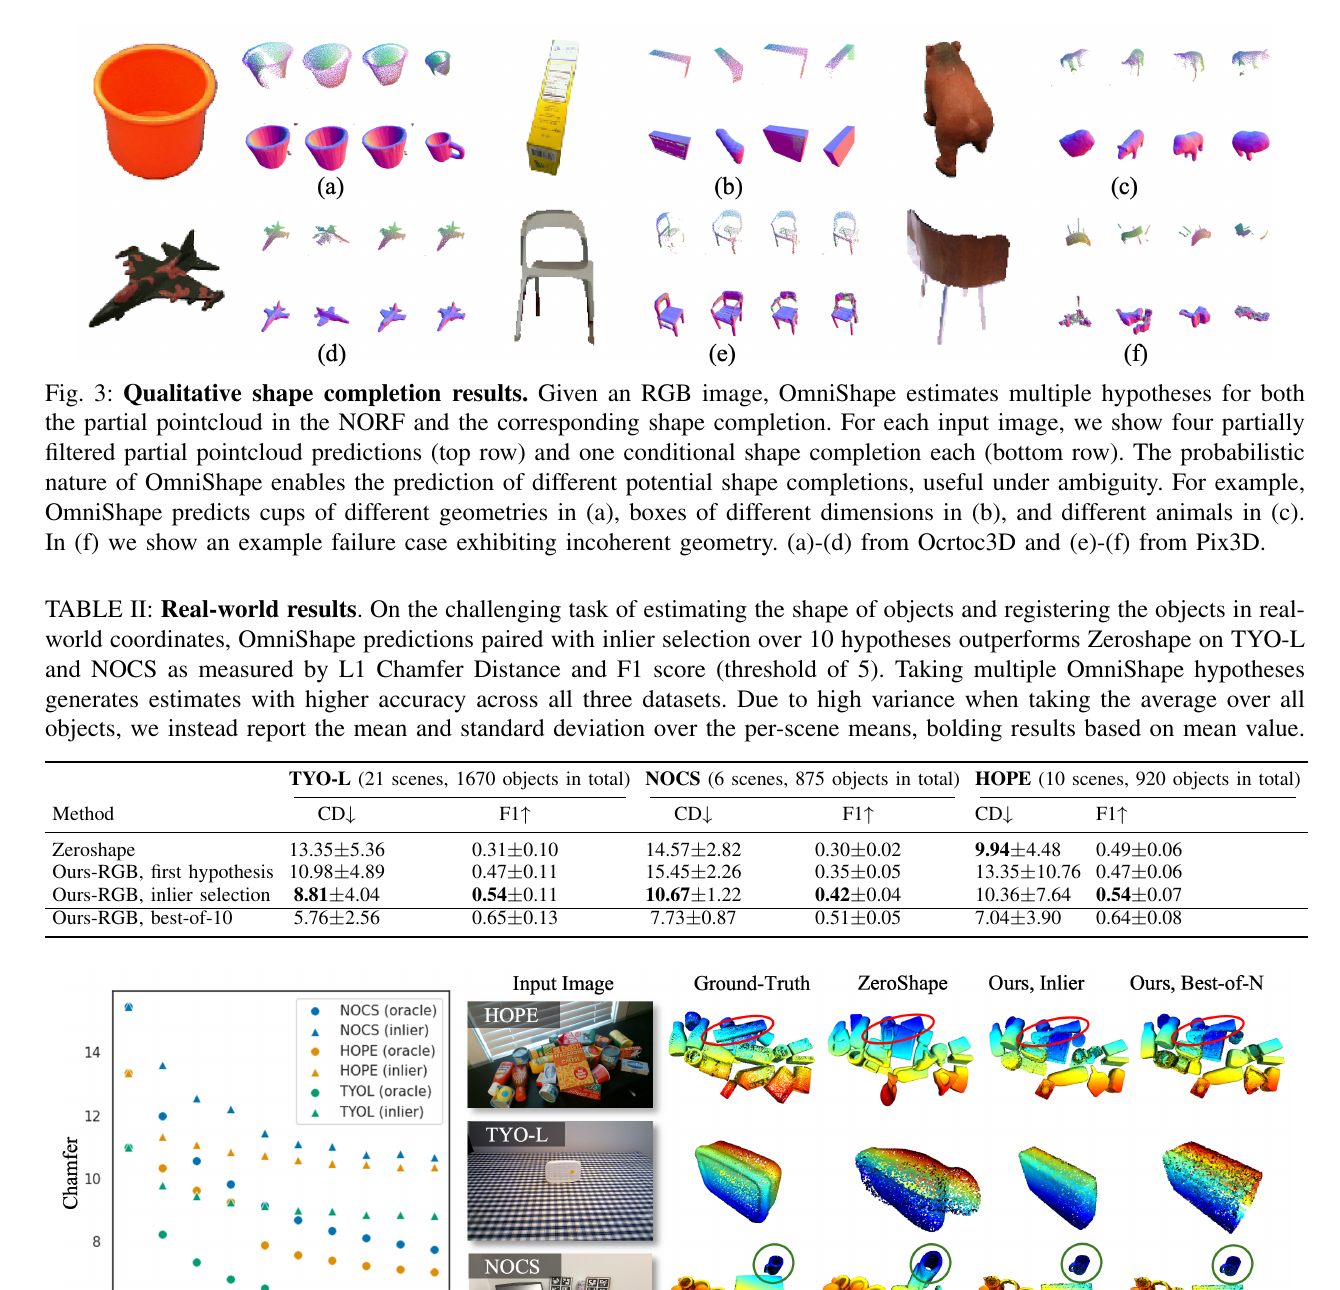
真实数据上,RGB inlier selection:
| 数据集 | Chamfer ↓ | F1 ↑ |
|---|---|---|
| TYO-L | 8.81 ± 4.04 | 0.54 ± 0.11 |
| NOCS | 10.67 ± 1.22 | 0.42 ± 0.04 |
| HOPE | 10.36 ± 7.64 | 0.54 ± 0.07 |
Best-of-10 更高,例如 TYO-L 达 5.76 / 0.65;但这是 oracle 上界,不是系统自动选择能稳定达到的结果。
5. 粗读结论
OmniShape 的核心不是把一个 mesh 做得更精细,而是承认单图补全存在多解,并让 shape 与 pose 共同采样。它适合无目标 CAD 的新对象建模;若应用要求唯一、实时、毫米级位姿,还需要更强的 hypothesis ranking 与 metric registration。